محاكاة تفاعلية
محاكاة متحكم PID
اضبط Kp / Ki / Kd على حلقة حرارية حية — التجاوز، الاستقرار، الاضطرابات.
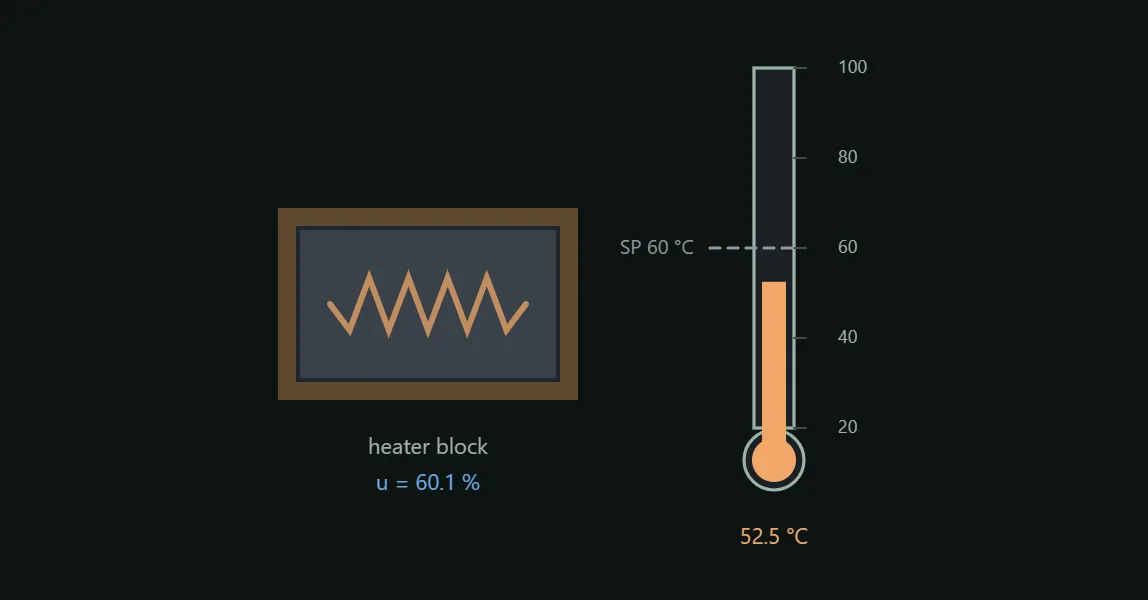
Move the setpoint to command a step and watch the orange temperature chase it — raise Kp for speed and Ki to kill the offset. Kd is the interesting one here, because this block is a single lag with no transport delay: derivative action has no second pole for its phase lead to cancel, so it buys no damping at all. It only adds effective thermal mass — it slows the rise, and it makes the Overshoot readout beside it steadily worse all the way up the slider. Derivative earns its keep on a process with a second lag or a measurement delay; watch this one refuse it. Hit Disturbance to knock 8 °C off and see the loop recover, or Restart to put the block back at ambient with an empty integrator. The graph is anchored on the last change: x = 0 is that instant and everything left of it is history. The run stops once the loop has stopped moving — with Ki = 0 that is an offset BELOW the setpoint, because a proportional controller needs a standing error to produce any output at all.